Edge computing on unmanned aerial vehicles (UAVs) enables low-latency wildfire monitoring by performing visual inference onboard; however, practical deployment is constrained by limited labeled data and resource budgets that often preclude reliance on large GPU...
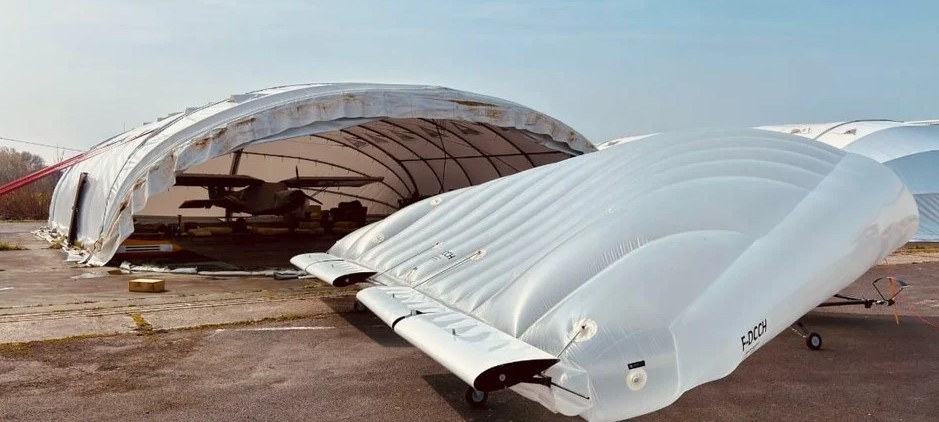
Mentre gran parte del settore della logistica aerea punta su velivoli e droni sempre più veloci, pesanti e capaci di coprire distanze enormi con carichi massicci, c’è chi ha deciso di invertire totalmente la rotta con un progetto davvero fuori dal comune. La...
Unmanned aerial vehicle (UAV) identification in edge environments requires both high classification accuracy and efficient real-time deployment on lightweight hardware. This study presents LUMEN, a Lightweight UAV Multi-Enhanced Network designed for...
Wireless resource allocation in digital-twin-enabled unmanned aerial vehicle (UAV) swarms must be both network-feasible and certifiably safe for closed-loop control. Existing packet-level or scalar-priority schedulers cannot meaningfully compare heterogeneous...
UAV path planning in complex three-dimensional obstacle environments requires a balance between search efficiency and flight feasibility. However, existing RRT*-based methods often fail to satisfy this requirement, as their random sampling lacks directional guidance...